carry1100lu.com
1100lu.com 时间:2021-03-22 阅读:()
DesignofexperimentalbenchbasedonmotioncontrollerHong-YanSHI1,a,1InnerMongoliaUniversityfortheNationalities,CollegeofMechanicalEngineering,TongLiao,028000,China.
ajdxashy@126.
comKeywords:Experimentalbench,Motioncontroller,Controlsystem.
Abstract.
Thenumericalcontroltechnologyisanimportantindicatortomeasureacountry'scomprehensivenationalstrengthandnationaldefensestrength,withthecontinuousdevelopmentofChina'sscienceandtechnology,NCtechnologyhasbeengreatlyimproved,atthesametime,NCpersonnelisalsorequiredcorrespondingly.
Buttheproblemsofpoorexperimentalconditionsintheprocessofpersonneltrainingisexist,itcannotdoverywellinpracticalteaching,akindofexperimentalbenchisdesignedbasedonthemotioncontrollerinthispaper,thebenchhastheadvantagesofsimplestructure,itiseconomicalandpractical,whichprovidesanewwayfortheteachingofnumericalcontroltechnology.
IntroductionAfteryearsofdevelopment,CNCtechnologyhasbecomethecoreofmodernmanufacturingtechnology[1].
ThelevelofCNCequipment,CNCtechnologyownershipandmanufacturingcapabilitiesofCNCequipmenthavebecomeanimportantsymboltomeasureacountry'slevelofindustrialmodernization.
Thedevelopmentofnumericalcontroltechnologyisthefoundationofnationaldefenseconstructionandtheguaranteeofnationaleconomicdevelopment[2].
WiththedevelopmentofChina'seconomyandtheprogressofscienceandtechnology,themanufacturingindustryhasputforwardhigherrequirementsforequipment,numericalcontrolequipmenthasbecometheinevitabletrendofthedevelopmentofCNCtechnology,integratedpersonnelisurgentlyneeded,anditputsforwardhigherrequirementsontheCNCtalentscultivation[3].
ButthetrainingofNCpersonnelinourcountryhascertainproblems,themainreasonare,thecurriculumandteachingcontentisnotreasonable,equipmentisbackward[4].
Butthenumericalcontroltechnologyandelectromechanicalintegrationtechnologyarepracticaltechnology,itmustcarryonthepracticeexperience,theexperimentalconditionsareinsufficienttomeetthedemandoftheteaching[5].
Inthispaper,kindofexperimentalbenchisdesignedbasedonthemotioncontroller,thebenchhastheadvantagesofsimplestructure,itiseconomicalandpractical,itcaneffectivelysolvetheproblemofinsufficientexperimentalconditions.
Ithasacertainpracticalsignificance.
OveralldesignofthebenchThemechanicalstructuredesignofthebench.
Thebenchhastwodegreesoffreedom,respectivelytheyareXandYdirections.
ItisshowninFigure1,thebenchisdrivenbytwomotors,servomotorisconnectedwiththeballscrewthroughthegearmechanism,theballscrewisconnectedwiththebench,theservomotorrotatestodrivethebench.
Aphotoelectricswitchisputonthebench,whichisusedtocontrolthebenchtofindzero,itprovidedwithalimitswitchattheendofthebench,soastopreventtheoverrunmovementofthebench,itisusedtoensuretheworkstationsafety.
1.
Limitswitch2.
Bench3.
Zeroreturningswitch4.
Yaxismotor5.
XaxismotorFigure1.
ThemechanicalstructuredesignThecontrolsystemdesignofthebench.
ThecontrolsystemofthebenchisshowninFigure2,thecontrolsystemconsistsofPCmachine,motioncontroller,servodriverandservomotor.
Thecoreofthecontrolsystemisthemotioncontroller,motioncontrollerreceivesthesignalfromthePCmachine,andcontrolsthebench,thebenchmakesthecorrespondingmovement.
ThePCandmotioncontrollerisconnectedbyEthernet,theycancommunicatedirectly.
Zeroreturningswitchandlimitswitcharedirectlyconnectedwiththemotioncontroller,inthemotionofthebench,ifthezeroreturningswitchorthelimitswitchistriggered,thesystemautomaticallyreceivesthefeedbacksignal,andmakesthecorrespondingactionaccordingtoprogramtocontrolthebench.
Figure2.
ThehardwareintegrationSoftwaredesignSoftwarestructuredesign.
Themotioncontrolleristhecoreofthecontrolsystemofthebench.
AsshowninFigure3,thecontrolsystemusestheformofupperandlowercomputer.
ThemotioncontrollerisoperatedbasedonPC,itonlyhastheoperationenvironment,thereisnodevelopmentenvironment,soitisnecessarytousePCasthehostmachine,motioncontrollerasslavemachine.
AsshowninFigure4,thesoftwaredesignadoptsmodularization,hierarchicalway,theyaredividedintomanagementmodule,parametermodule,motioncontrolmoduleaccordingtothedifferentlevels.
ThemanagementmoduleandthemoduleparametersarecompletedbyPC,includingthepreparationandmanagement,programsettingsanddisplay;themotioncontrolmoduleiscompletedbythemotioncontroller,includingmotioncontrolandlogiccontrol.
Figure3.
ThemodeofcontrolsystemManagementmoduleParametermoduleMotioncontrolmoduleFigure4.
ThemodulardesignofsoftwareI/Odesign.
ThesendingandreceivingsignalisofsystemthroughtheI/Ointerfaceofcontroller,includingthezeroreturningsignals,limitsignals,indicationsignal,etc.
ThedesignofI/Osystemisshownintable1.
Table1.
SystemI/OdesignInputOutputIN0ZeroreturningOUT0Indicationsignal1signal1IN1ZeroreturningOUT1Indicationsignal2signal2IN2Limitsignal1OUT2Indicationsignal3IN3Limitsignal2OUT3Indicationsignal4OUT4Indicationsignal5OUT5Indicationsignal6Programflowdesign.
Programflowdesignisshowninfigure5.
Firstofall,thesystemdoesinitialization,inspectingoperationstateofsystem,ifthereisanerror,thesystemwillbegiveninstructions,ifthereisnoerror,aftertheinitialization,XaxisandYaxisrespectivelycomesbacktotheorigin,thensetparameterprogramming.
Itcanbeprogrammedonlyafterdeterminingthebenchreferencepoint,otherwisethereisnoprogrammingreference,itmaycausethebenchcross-borderoperation.
Afterprogrammingthebenchwillmovecorrespondingly,ifthebenchisbeyondthelimitswitchposition,thesystemwillautomaticallystoprunningandalarm.
Theoperatingstatuscanbeobservedintheprocessofmovement,includingtheXandYaxisvelocityanddisplacementetc.
Figure5.
WorkflowSummaryAccordingtotheproblemofinsufficientexperimentalconditionsinthecourseofCNCtechnologyandelectromechanicalintegrationof,akindofexperimentalbenchisdesignedbasedonthemotioncontrollerinthispaper,thebenchcanbeusedforCNCtechnologyormechatronicscourse,althoughthissystemcannotachievethehigh-endCNCsystem,butthissystemiseconomicalandpractical,itisspecificallyforteachingthedevelopment,operationandmaintenancecostsarenothigh,iteffectivelysolvesthedifficultproblemofthestudents.
AnewmethodisproposedforthetrainingofNCtechnologyandmechatronicstalents.
References[1]WenGuang,MaHongwei.
CurrentsituationanddevelopmenttrendofCNCtechnology[J].
MechanicalEngineer,2003,(1):9-12.
[2]ZhangFuyuan,FangJianglong.
OnthedevelopmentofCNCtechnologyinChina[J].
Chinesemechanicalengineering,1999,10(10):1100-1103.
[3]LuQijian,LiuMingdeng.
Advancesinnumericalcontroltechnology[J].
Manufacturingtechnologyandmachinetool,2002,(5):5-7.
[4]JiHuaTian.
DemandanalysisofNCtechnicalpersonnel[J].
LiaoningJournalofhighervocationaleducation,2008,10(7):27-28.
[5]WangHaigen,ChengGuobiao,FangZhufang.
ExploringtheNCtechnologypracticeteaching[J].
Experimentaltechnologyandmanagement,2008,25(2):92-94.
ajdxashy@126.
comKeywords:Experimentalbench,Motioncontroller,Controlsystem.
Abstract.
Thenumericalcontroltechnologyisanimportantindicatortomeasureacountry'scomprehensivenationalstrengthandnationaldefensestrength,withthecontinuousdevelopmentofChina'sscienceandtechnology,NCtechnologyhasbeengreatlyimproved,atthesametime,NCpersonnelisalsorequiredcorrespondingly.
Buttheproblemsofpoorexperimentalconditionsintheprocessofpersonneltrainingisexist,itcannotdoverywellinpracticalteaching,akindofexperimentalbenchisdesignedbasedonthemotioncontrollerinthispaper,thebenchhastheadvantagesofsimplestructure,itiseconomicalandpractical,whichprovidesanewwayfortheteachingofnumericalcontroltechnology.
IntroductionAfteryearsofdevelopment,CNCtechnologyhasbecomethecoreofmodernmanufacturingtechnology[1].
ThelevelofCNCequipment,CNCtechnologyownershipandmanufacturingcapabilitiesofCNCequipmenthavebecomeanimportantsymboltomeasureacountry'slevelofindustrialmodernization.
Thedevelopmentofnumericalcontroltechnologyisthefoundationofnationaldefenseconstructionandtheguaranteeofnationaleconomicdevelopment[2].
WiththedevelopmentofChina'seconomyandtheprogressofscienceandtechnology,themanufacturingindustryhasputforwardhigherrequirementsforequipment,numericalcontrolequipmenthasbecometheinevitabletrendofthedevelopmentofCNCtechnology,integratedpersonnelisurgentlyneeded,anditputsforwardhigherrequirementsontheCNCtalentscultivation[3].
ButthetrainingofNCpersonnelinourcountryhascertainproblems,themainreasonare,thecurriculumandteachingcontentisnotreasonable,equipmentisbackward[4].
Butthenumericalcontroltechnologyandelectromechanicalintegrationtechnologyarepracticaltechnology,itmustcarryonthepracticeexperience,theexperimentalconditionsareinsufficienttomeetthedemandoftheteaching[5].
Inthispaper,kindofexperimentalbenchisdesignedbasedonthemotioncontroller,thebenchhastheadvantagesofsimplestructure,itiseconomicalandpractical,itcaneffectivelysolvetheproblemofinsufficientexperimentalconditions.
Ithasacertainpracticalsignificance.
OveralldesignofthebenchThemechanicalstructuredesignofthebench.
Thebenchhastwodegreesoffreedom,respectivelytheyareXandYdirections.
ItisshowninFigure1,thebenchisdrivenbytwomotors,servomotorisconnectedwiththeballscrewthroughthegearmechanism,theballscrewisconnectedwiththebench,theservomotorrotatestodrivethebench.
Aphotoelectricswitchisputonthebench,whichisusedtocontrolthebenchtofindzero,itprovidedwithalimitswitchattheendofthebench,soastopreventtheoverrunmovementofthebench,itisusedtoensuretheworkstationsafety.
1.
Limitswitch2.
Bench3.
Zeroreturningswitch4.
Yaxismotor5.
XaxismotorFigure1.
ThemechanicalstructuredesignThecontrolsystemdesignofthebench.
ThecontrolsystemofthebenchisshowninFigure2,thecontrolsystemconsistsofPCmachine,motioncontroller,servodriverandservomotor.
Thecoreofthecontrolsystemisthemotioncontroller,motioncontrollerreceivesthesignalfromthePCmachine,andcontrolsthebench,thebenchmakesthecorrespondingmovement.
ThePCandmotioncontrollerisconnectedbyEthernet,theycancommunicatedirectly.
Zeroreturningswitchandlimitswitcharedirectlyconnectedwiththemotioncontroller,inthemotionofthebench,ifthezeroreturningswitchorthelimitswitchistriggered,thesystemautomaticallyreceivesthefeedbacksignal,andmakesthecorrespondingactionaccordingtoprogramtocontrolthebench.
Figure2.
ThehardwareintegrationSoftwaredesignSoftwarestructuredesign.
Themotioncontrolleristhecoreofthecontrolsystemofthebench.
AsshowninFigure3,thecontrolsystemusestheformofupperandlowercomputer.
ThemotioncontrollerisoperatedbasedonPC,itonlyhastheoperationenvironment,thereisnodevelopmentenvironment,soitisnecessarytousePCasthehostmachine,motioncontrollerasslavemachine.
AsshowninFigure4,thesoftwaredesignadoptsmodularization,hierarchicalway,theyaredividedintomanagementmodule,parametermodule,motioncontrolmoduleaccordingtothedifferentlevels.
ThemanagementmoduleandthemoduleparametersarecompletedbyPC,includingthepreparationandmanagement,programsettingsanddisplay;themotioncontrolmoduleiscompletedbythemotioncontroller,includingmotioncontrolandlogiccontrol.
Figure3.
ThemodeofcontrolsystemManagementmoduleParametermoduleMotioncontrolmoduleFigure4.
ThemodulardesignofsoftwareI/Odesign.
ThesendingandreceivingsignalisofsystemthroughtheI/Ointerfaceofcontroller,includingthezeroreturningsignals,limitsignals,indicationsignal,etc.
ThedesignofI/Osystemisshownintable1.
Table1.
SystemI/OdesignInputOutputIN0ZeroreturningOUT0Indicationsignal1signal1IN1ZeroreturningOUT1Indicationsignal2signal2IN2Limitsignal1OUT2Indicationsignal3IN3Limitsignal2OUT3Indicationsignal4OUT4Indicationsignal5OUT5Indicationsignal6Programflowdesign.
Programflowdesignisshowninfigure5.
Firstofall,thesystemdoesinitialization,inspectingoperationstateofsystem,ifthereisanerror,thesystemwillbegiveninstructions,ifthereisnoerror,aftertheinitialization,XaxisandYaxisrespectivelycomesbacktotheorigin,thensetparameterprogramming.
Itcanbeprogrammedonlyafterdeterminingthebenchreferencepoint,otherwisethereisnoprogrammingreference,itmaycausethebenchcross-borderoperation.
Afterprogrammingthebenchwillmovecorrespondingly,ifthebenchisbeyondthelimitswitchposition,thesystemwillautomaticallystoprunningandalarm.
Theoperatingstatuscanbeobservedintheprocessofmovement,includingtheXandYaxisvelocityanddisplacementetc.
Figure5.
WorkflowSummaryAccordingtotheproblemofinsufficientexperimentalconditionsinthecourseofCNCtechnologyandelectromechanicalintegrationof,akindofexperimentalbenchisdesignedbasedonthemotioncontrollerinthispaper,thebenchcanbeusedforCNCtechnologyormechatronicscourse,althoughthissystemcannotachievethehigh-endCNCsystem,butthissystemiseconomicalandpractical,itisspecificallyforteachingthedevelopment,operationandmaintenancecostsarenothigh,iteffectivelysolvesthedifficultproblemofthestudents.
AnewmethodisproposedforthetrainingofNCtechnologyandmechatronicstalents.
References[1]WenGuang,MaHongwei.
CurrentsituationanddevelopmenttrendofCNCtechnology[J].
MechanicalEngineer,2003,(1):9-12.
[2]ZhangFuyuan,FangJianglong.
OnthedevelopmentofCNCtechnologyinChina[J].
Chinesemechanicalengineering,1999,10(10):1100-1103.
[3]LuQijian,LiuMingdeng.
Advancesinnumericalcontroltechnology[J].
Manufacturingtechnologyandmachinetool,2002,(5):5-7.
[4]JiHuaTian.
DemandanalysisofNCtechnicalpersonnel[J].
LiaoningJournalofhighervocationaleducation,2008,10(7):27-28.
[5]WangHaigen,ChengGuobiao,FangZhufang.
ExploringtheNCtechnologypracticeteaching[J].
Experimentaltechnologyandmanagement,2008,25(2):92-94.
- carry1100lu.com相关文档
- dust1100lu.com
- pruning1100lu.com
- performed1100lu.com
- Hove1100lu.com
- 移植1100lu.com
- 熔融1100lu.com
hosthatch:14个数据中心15美元/年
hosthatch在做美国独立日促销,可能你会说这操作是不是晚了一个月?对,为了准备资源等,他们拖延到现在才有空,这次是针对自己全球14个数据中心的VPS。提前示警:各个数据中心的网络没有一个是针对中国直连的,都会绕道而且ping值比较高,想买的考虑清楚再说!官方网站:https://hosthatch.com所有VPS都基于KVM虚拟,支持PayPal在内的多种付款方式!芝加哥(大硬盘)VPS5...
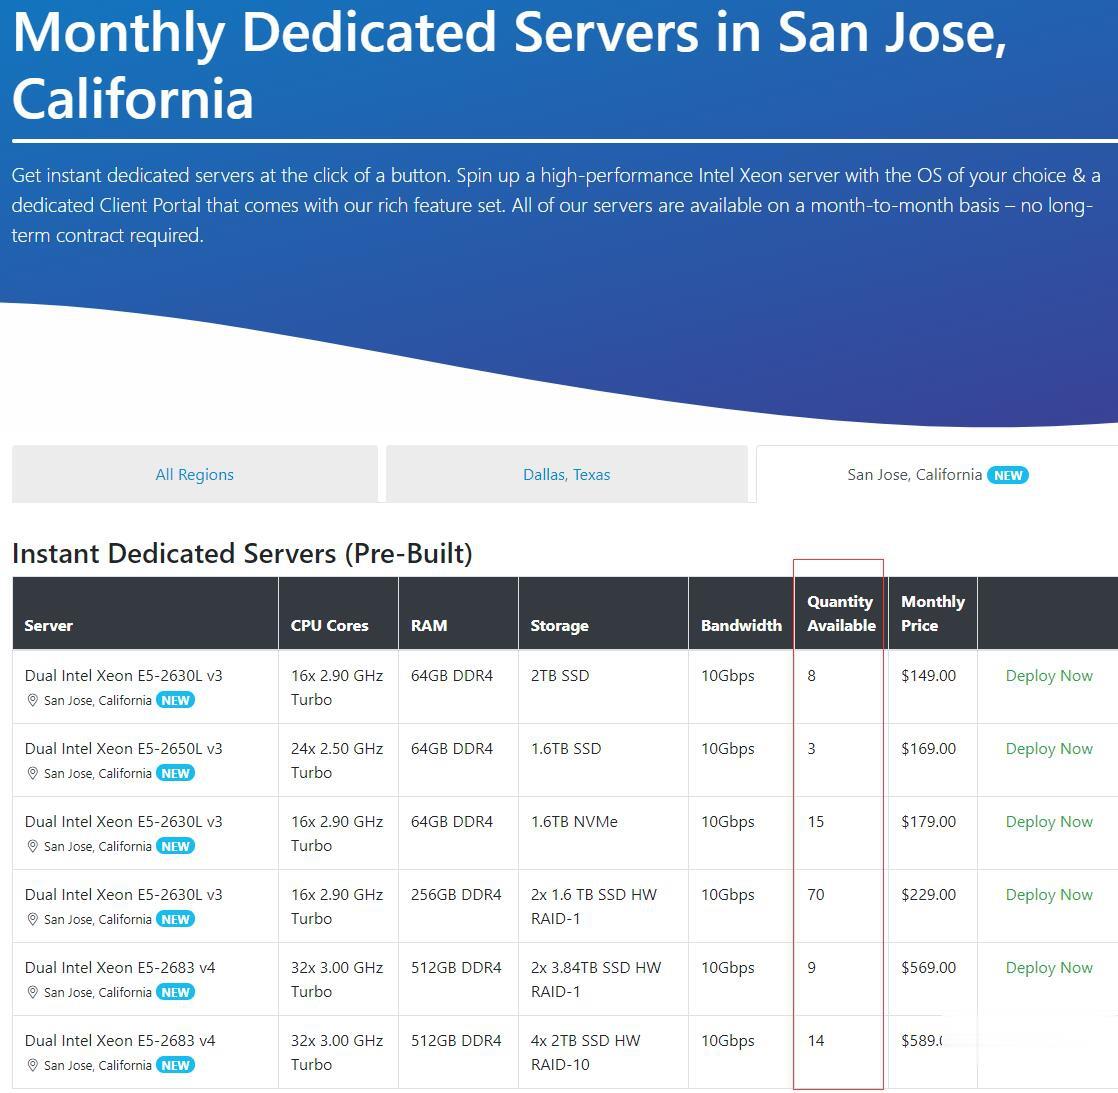
Spinservers:美国圣何塞机房少量补货/双E5/64GB DDR4/2TB SSD/10Gbps端口月流量10TB/$111/月
Chia矿机,Spinservers怎么样?Spinservers好不好,Spinservers大硬盘服务器。Spinservers刚刚在美国圣何塞机房补货120台独立服务器,CPU都是双E5系列,64-512GB DDR4内存,超大SSD或NVMe存储,数量有限,机器都是预部署好的,下单即可上架,无需人工干预,有需要的朋友抓紧下单哦。Spinservers是Majestic Hosting So...
SugarHosts新增Windows云服务器sugarhosts六折无限流量云服务器六折优惠
SugarHosts糖果主机商我们较早的站长们肯定是熟悉的,早年是提供虚拟主机起家的,如今一直还在提供虚拟主机,后来也有增加云服务器、独立服务器等。数据中心涵盖美国、德国、香港等。我们要知道大部分的海外主机商都只提供Linux系统云服务器。今天,糖果主机有新增SugarHosts夏季六折的优惠,以及新品Windows云服务器/云VPS上线。SugarHosts Windows系统云服务器有区分限制...
1100lu.com为你推荐
-
摩拜超15分钟加钱摩拜单车不是按骑行时间收费吗,我怎么只要开锁就要支付一元(而且只骑十几分钟)Baby被问婚变绯闻终于知道黄晓明为什么会娶baby蓝色骨头手机都是人类的骨头灰歌名是什么广东GDP破10万亿想知道广东城市的GDP排名广东GDP破10万亿__年,我国国内生产总值(GDP)首破10万亿元.目前,我国经济总量排名世界第___位?广东GDP破10万亿广东省2019年各市gdp是多少?www.983mm.com哪有mm图片?你懂得75ff.com开机出现www.ami.com是什么?怎么解决啊rawtoolsU盘显示是RAW格式怎么办rawtools佳能单反照相机的RAW、5.0M 是什么意思?