consistsqqshow.qq.com
qqshow.qq.com 时间:2021-03-23 阅读:()
TheOverallDesignoftheProductionLinePalletizingRobotBinHE1,a,Hai-NanNIU2,QuanLIU1,Yu-QiLIU31BeijingInformationScienceandTechnologyUniversity,China2Schoolofeconomicsandmanagement,ChangshaUniversityofScienceandTechnology,China3ZhouEnlaiSchoolofGovernment,NankaiUniversity,Chinaawfalw104@vip.
qq.
comKeywords:PalletizingManipulator,MechanicalStructure,Design.
Abstract.
Thisstudydescribestheproductionprocessofglassproductionlines;accordingtotheproductionprocessisdesignedtotakethelineterminalboardmanipulator,usingPro/Esoftwaretodesignthemechanicalstructureofthethree-dimensionalsimulation,butalsogivessomestandardpartsdesignandselection.
Completethecontrolstrategyoftherobot.
IntroductionIntheproductionline,palletizingrobotneedstobeabletoquicklyandaccuratelypickup,placeandhandlingobjects.
Theyshouldrequesthighprecision,fastresponse,certaincarryingcapacity,sufficientworkingspaceandflexiblefreedomandthepropertiescanbeautomaticallypositioningatanyposition.
Palletizingrobotdesignprincipleshave:Comprehensiveanalysisofthejobobjectofthetechnicalrequirementsofthejob,planningthemostreasonablejobprocessandtechnology,andtomeetthesystemfunctionalrequirementsandenvironmentalconditions;Clarifythestructureoftheworkpieceshapeandmaterialproperties,positioningaccuracy,crawl,mechanicalcharacteristicsduringtransportation,thesizeandqualityparameters,andtodeterminethestructureandoperationoftherobotcontrolrequirements;Asfaraspossibleselectionofstandardcomponents,simplifyingthedesignandmanufacturingprocess,takingintoaccountthegeneralandspecificnature,andcanachieveaflexibleconversionandprogrammingcontrol.
Thestudymanipulatorglassproductionlineautomaticpickplatepalletizingrobotissuitableforlargeorsmallandmediumglassproduction,canchangetheautomatichandlingoroperationofthedeviceoperationprocedures,safetyrequirements,professional,laborintensitylargeandoperationfrequentproductionmonotonousoccasion[3].
GlassPalletizingSystemIntroducedGlasspalletizingsystemisatypicalmechatronicsystem.
MechatronicSystemsconsistsofmechanicalsystems,electronicinformationprocessingsystems,powersystems,sensorsystems,actuatorsystem,anditsfunctionasthemainfunction,motorfunction,detection,control,structurefunction[4].
Intheglasspalletizingoperation,themostcommonproblemisthefragileglass,easytoscratch,likelytocausebodilyinjuryofstaff,inordertomeettheneedsofautomatedmachineryproduction,palletizingrobotemerged.
Palletizingrobothaspalletizingspeed,pickandplaceaccurate,andflexibleoperation,reducethelaborintensityandpersonalinjury,improvedworkingconditionsandreduceglassdamagerate.
Thedesignofthreemainmodules,thetransmissionmodule,flipmodule,stackingmodule.
Manipulatoroverall3DdesignisshowninFigure1.
1.
Fig.
1.
1GlassProductionLinePalletizingRobot3DDesignGlassMechanicalDesignAnalyzingthepalletizingrobotprocessistodeterminethemechanicalstructuredesign.
Accordingtodifferentfunctions,thedesignisdividedintotransmissionsystemdesign,flippingsystemdesign,stackingsystemdesign;thefollowingwereseparatelydesignedforeachsystem.
TransmissionSystemDesignDesignrobottransmissionsystemismainlydividedintostickdesignandtransmissionstentdesignaccordingtotherequirementsoftheoriginalglassproductionlines;transmissionrollerspacinganddiametertransmissionlinewiththepreviousdesignrequirementsarethesame,namelyaknownsize.
Its3DdesignisshowninFigure2.
1.
Transmissionrollerchaindrivesadoption,ononesideoftherollerinstallation.
Fig.
2.
1TransmissionSystem3DDesignFlipSystemDesignFlipsystemdesignismainlydividedintothesuckerarmdesignandcrankrockermechanismdesignintwoparts.
FlipoverallsystemdiagramshowninFigure2.
2.
Fig.
2.
2FlipOverallSystemDiagramSuckerArmDesign.
Accordingtothesizeoftheglass,theoverallsizeofthemanipulatorandthedistancebetweenthesinglesuctioncuparmandthestructuresizearecalculated.
Minimumsizeofglassis400mm*400mm,Maximumsizeis2000mm*2000mm,thedistancebetweentheindividualsuctioncuparmisd':Rollerdiameterd6,taken=5.
Its3DmodelingdiagramisshowninFigure2.
3.
Fig.
2.
3MechanicalHandSuctionCupArm3DDesign(1-smallarm;2-arm)Intheprocessofstackingglassproductionline,itisnecessarytotakeaglassfromtherollersdown,followtheprincipleoftakingflatlevel,thusliftingdeviceselectionparallelogramlinkage.
Verticalparallelogramlinkagerodthatisparallelandequallengthdoublecrankmechanism,ithasamemberissimple,easymanufacturing,lowvicestructure,hightransmissionaccuracy,wearresistance,etc.
,anddrivemeanscooperatingtoachieveglasspickandplace,thelevelofmobilepositioning[1].
Positioningtheliftingdisplacementoftheparallelquadrilateralmechanism200mm,Theanglebetweenthecrankandconnectingrodas45°,thelengthofthecranklcrank=200*≈350mm.
Fig.
2.
4TransverseLinksEnlargedViewSincethepneumaticdrivesystemmovesquickly,responsive,resistanceandleakagelossissmall,lowcost,andthereforethedrivechuckframeusingpneumatictransmissionmode[5].
MountingpositionofthecylindershowninFigure2.
3,theinvertarmisdesignedtoformaU-shapedgroove,bothtopreventtheerosionofdustonthecylinder,themanufacturingprocessissimple,andcanreducethedifficultyofinstallationofthecylinder.
WhichisinstalledintheU-shapedgrooveonlytwocylinders,theotherU-lineslotsareconnectedwiththesuckerrodholder,eachU-shapedgrooveofthecylinderrodwithahorizontalrodconnectedtoapartiallyenlargeddiagraminFigure2.
4shown,sonotonlyreducesthenumberofcylinders,andreducingcosts.
CrankRockerMechanism.
Thisdesignwillcrankrockermechanismdesignintheformoftwointerconnected,asshowninFigure2.
5,onlyonesetofamotor-drivencrankrockermechanism,flipthearmsonbothsidesofthetwogroupscanbedrivenbyadriverod,bothtoreducethenumberofmotors,butalsoreducesthesuctioncuparmshakingduringexercise,increasingthestabilityandreliabilityoftheentireorganization.
Slider-crankmechanismandthereversingmechanismraillinkandformaquadrangle,therearetwoextremepositionsofthequadrilateralformatriangleABCwhenthecrankandconnectingrodcollinear,whenthecrankandarailline,connectingrodrailandfliparmformanothertriangleDBE.
Flipknownlengthofthearmandtherailbase,accordingtotherelationshipbetweenthesidesofatriangletheorem,trianglelawofcosines,transmissionangleγmin≥40°~50°(γmin=40°)Calculatethelengthofthecrankandrocker.
Take∠ABC=110°,∠BDE=30°,lAB=1000mm.
Bythelawofcosinescanbeobtained:=(2.
1)(2.
2)Bythesidesofatrianglerelationtheoremcanbeobtained:(2.
3)(2.
4),000mm,:,.
Fig.
2.
5CrankRockerMechanism3DDesignFig.
2.
6SingleCrankRockerMechanismTrajectoryDesignStackingSystemDesignAstackedshapedstentusingthestentaccordingtothemaximumsizeoftheglass2000*2000mm,theminimumsizeof400*400mm,theheightofthestentmaybedesignedto2mm,awidthof2mm,theanglebetweenthebracketandthehorizontalarmcanbesetflipangle,i.
e.
θ=180°-110°=70°.
AsshowninFigure2.
7,inordertoplacethevarioussizesofglass,theintermediatesupportstructuremadeofbeams,theminimumsizemaybeheightglasstransomwiththebottomsurfaceofthestentbetweentobe,thatis,h=400mm.
Thedesignofthestentisdesignedtobeslidablealongtheguiderailform,whichcaneffectivelypreventthephenomenonoftheglassrollstackingprocessbecauseofvaryingqualitycausedbythemountingbrackets,increasethestabilityofthestentandthestentcanslidealongtheguiderail,flexibleConvenience.
Fig.
2.
7StackedGlassHolderSummaryThischapteranalyzestheprocessofpalletizingrobotdesigned3Dmapeachsection.
Thischapterfocusesontheinvertarmmechanism,suckerarmmechanism,rockermechanism,stackingbracketFigure3Dmodeling,andtheuseofPro/Edesignthree-dimensionalmodel,andderivetwo-dimensionaldesigndrawings.
Althoughthedesignisnotthebest,butaftertheredesignandimprovementofacertainmodel,itisofgreatsignificanceforimprovingtheefficiencyofglassproductionlinepalletizing.
References[1]WangZhong.
Itsapplicationtoexpandtheparallelogrammechanism[J].
MechanicalDesign.
2005,(12):504~530.
[2]Michalingliar.
Solarenergyusingforhydrogenproduction[J].
PetroleumandCoal.
2007.
[3]FengGui-ming,ZhaoHai-xue.
Ontheultra-whiterolledglassphotovoltaiccommonmoldingdefects[J].
Glass.
2011(10):21to23.
[4]TianDa-wei.
Researchonmechatronics[J].
OnlineeducationnetworkHerald.
2012(45):96~99.
[5]XieXue-mei.
Experimentalstudyofglassdefectsdetectionsystem[D].
Qingdao:ChinaOceanUniversity.
2008.
05.
[6]ZhouYang.
Glassqualityonlinedetectionalgorithmresearchandsystemimplementation[D].
Wuhan:HuazhongUniversityofScienceandTechnology.
2006.
04.
qq.
comKeywords:PalletizingManipulator,MechanicalStructure,Design.
Abstract.
Thisstudydescribestheproductionprocessofglassproductionlines;accordingtotheproductionprocessisdesignedtotakethelineterminalboardmanipulator,usingPro/Esoftwaretodesignthemechanicalstructureofthethree-dimensionalsimulation,butalsogivessomestandardpartsdesignandselection.
Completethecontrolstrategyoftherobot.
IntroductionIntheproductionline,palletizingrobotneedstobeabletoquicklyandaccuratelypickup,placeandhandlingobjects.
Theyshouldrequesthighprecision,fastresponse,certaincarryingcapacity,sufficientworkingspaceandflexiblefreedomandthepropertiescanbeautomaticallypositioningatanyposition.
Palletizingrobotdesignprincipleshave:Comprehensiveanalysisofthejobobjectofthetechnicalrequirementsofthejob,planningthemostreasonablejobprocessandtechnology,andtomeetthesystemfunctionalrequirementsandenvironmentalconditions;Clarifythestructureoftheworkpieceshapeandmaterialproperties,positioningaccuracy,crawl,mechanicalcharacteristicsduringtransportation,thesizeandqualityparameters,andtodeterminethestructureandoperationoftherobotcontrolrequirements;Asfaraspossibleselectionofstandardcomponents,simplifyingthedesignandmanufacturingprocess,takingintoaccountthegeneralandspecificnature,andcanachieveaflexibleconversionandprogrammingcontrol.
Thestudymanipulatorglassproductionlineautomaticpickplatepalletizingrobotissuitableforlargeorsmallandmediumglassproduction,canchangetheautomatichandlingoroperationofthedeviceoperationprocedures,safetyrequirements,professional,laborintensitylargeandoperationfrequentproductionmonotonousoccasion[3].
GlassPalletizingSystemIntroducedGlasspalletizingsystemisatypicalmechatronicsystem.
MechatronicSystemsconsistsofmechanicalsystems,electronicinformationprocessingsystems,powersystems,sensorsystems,actuatorsystem,anditsfunctionasthemainfunction,motorfunction,detection,control,structurefunction[4].
Intheglasspalletizingoperation,themostcommonproblemisthefragileglass,easytoscratch,likelytocausebodilyinjuryofstaff,inordertomeettheneedsofautomatedmachineryproduction,palletizingrobotemerged.
Palletizingrobothaspalletizingspeed,pickandplaceaccurate,andflexibleoperation,reducethelaborintensityandpersonalinjury,improvedworkingconditionsandreduceglassdamagerate.
Thedesignofthreemainmodules,thetransmissionmodule,flipmodule,stackingmodule.
Manipulatoroverall3DdesignisshowninFigure1.
1.
Fig.
1.
1GlassProductionLinePalletizingRobot3DDesignGlassMechanicalDesignAnalyzingthepalletizingrobotprocessistodeterminethemechanicalstructuredesign.
Accordingtodifferentfunctions,thedesignisdividedintotransmissionsystemdesign,flippingsystemdesign,stackingsystemdesign;thefollowingwereseparatelydesignedforeachsystem.
TransmissionSystemDesignDesignrobottransmissionsystemismainlydividedintostickdesignandtransmissionstentdesignaccordingtotherequirementsoftheoriginalglassproductionlines;transmissionrollerspacinganddiametertransmissionlinewiththepreviousdesignrequirementsarethesame,namelyaknownsize.
Its3DdesignisshowninFigure2.
1.
Transmissionrollerchaindrivesadoption,ononesideoftherollerinstallation.
Fig.
2.
1TransmissionSystem3DDesignFlipSystemDesignFlipsystemdesignismainlydividedintothesuckerarmdesignandcrankrockermechanismdesignintwoparts.
FlipoverallsystemdiagramshowninFigure2.
2.
Fig.
2.
2FlipOverallSystemDiagramSuckerArmDesign.
Accordingtothesizeoftheglass,theoverallsizeofthemanipulatorandthedistancebetweenthesinglesuctioncuparmandthestructuresizearecalculated.
Minimumsizeofglassis400mm*400mm,Maximumsizeis2000mm*2000mm,thedistancebetweentheindividualsuctioncuparmisd':Rollerdiameterd
Its3DmodelingdiagramisshowninFigure2.
3.
Fig.
2.
3MechanicalHandSuctionCupArm3DDesign(1-smallarm;2-arm)Intheprocessofstackingglassproductionline,itisnecessarytotakeaglassfromtherollersdown,followtheprincipleoftakingflatlevel,thusliftingdeviceselectionparallelogramlinkage.
Verticalparallelogramlinkagerodthatisparallelandequallengthdoublecrankmechanism,ithasamemberissimple,easymanufacturing,lowvicestructure,hightransmissionaccuracy,wearresistance,etc.
,anddrivemeanscooperatingtoachieveglasspickandplace,thelevelofmobilepositioning[1].
Positioningtheliftingdisplacementoftheparallelquadrilateralmechanism200mm,Theanglebetweenthecrankandconnectingrodas45°,thelengthofthecranklcrank=200*≈350mm.
Fig.
2.
4TransverseLinksEnlargedViewSincethepneumaticdrivesystemmovesquickly,responsive,resistanceandleakagelossissmall,lowcost,andthereforethedrivechuckframeusingpneumatictransmissionmode[5].
MountingpositionofthecylindershowninFigure2.
3,theinvertarmisdesignedtoformaU-shapedgroove,bothtopreventtheerosionofdustonthecylinder,themanufacturingprocessissimple,andcanreducethedifficultyofinstallationofthecylinder.
WhichisinstalledintheU-shapedgrooveonlytwocylinders,theotherU-lineslotsareconnectedwiththesuckerrodholder,eachU-shapedgrooveofthecylinderrodwithahorizontalrodconnectedtoapartiallyenlargeddiagraminFigure2.
4shown,sonotonlyreducesthenumberofcylinders,andreducingcosts.
CrankRockerMechanism.
Thisdesignwillcrankrockermechanismdesignintheformoftwointerconnected,asshowninFigure2.
5,onlyonesetofamotor-drivencrankrockermechanism,flipthearmsonbothsidesofthetwogroupscanbedrivenbyadriverod,bothtoreducethenumberofmotors,butalsoreducesthesuctioncuparmshakingduringexercise,increasingthestabilityandreliabilityoftheentireorganization.
Slider-crankmechanismandthereversingmechanismraillinkandformaquadrangle,therearetwoextremepositionsofthequadrilateralformatriangleABCwhenthecrankandconnectingrodcollinear,whenthecrankandarailline,connectingrodrailandfliparmformanothertriangleDBE.
Flipknownlengthofthearmandtherailbase,accordingtotherelationshipbetweenthesidesofatriangletheorem,trianglelawofcosines,transmissionangleγmin≥40°~50°(γmin=40°)Calculatethelengthofthecrankandrocker.
Take∠ABC=110°,∠BDE=30°,lAB=1000mm.
Bythelawofcosinescanbeobtained:=(2.
1)(2.
2)Bythesidesofatrianglerelationtheoremcanbeobtained:(2.
3)(2.
4),000mm,:,.
Fig.
2.
5CrankRockerMechanism3DDesignFig.
2.
6SingleCrankRockerMechanismTrajectoryDesignStackingSystemDesignAstackedshapedstentusingthestentaccordingtothemaximumsizeoftheglass2000*2000mm,theminimumsizeof400*400mm,theheightofthestentmaybedesignedto2mm,awidthof2mm,theanglebetweenthebracketandthehorizontalarmcanbesetflipangle,i.
e.
θ=180°-110°=70°.
AsshowninFigure2.
7,inordertoplacethevarioussizesofglass,theintermediatesupportstructuremadeofbeams,theminimumsizemaybeheightglasstransomwiththebottomsurfaceofthestentbetweentobe,thatis,h=400mm.
Thedesignofthestentisdesignedtobeslidablealongtheguiderailform,whichcaneffectivelypreventthephenomenonoftheglassrollstackingprocessbecauseofvaryingqualitycausedbythemountingbrackets,increasethestabilityofthestentandthestentcanslidealongtheguiderail,flexibleConvenience.
Fig.
2.
7StackedGlassHolderSummaryThischapteranalyzestheprocessofpalletizingrobotdesigned3Dmapeachsection.
Thischapterfocusesontheinvertarmmechanism,suckerarmmechanism,rockermechanism,stackingbracketFigure3Dmodeling,andtheuseofPro/Edesignthree-dimensionalmodel,andderivetwo-dimensionaldesigndrawings.
Althoughthedesignisnotthebest,butaftertheredesignandimprovementofacertainmodel,itisofgreatsignificanceforimprovingtheefficiencyofglassproductionlinepalletizing.
References[1]WangZhong.
Itsapplicationtoexpandtheparallelogrammechanism[J].
MechanicalDesign.
2005,(12):504~530.
[2]Michalingliar.
Solarenergyusingforhydrogenproduction[J].
PetroleumandCoal.
2007.
[3]FengGui-ming,ZhaoHai-xue.
Ontheultra-whiterolledglassphotovoltaiccommonmoldingdefects[J].
Glass.
2011(10):21to23.
[4]TianDa-wei.
Researchonmechatronics[J].
OnlineeducationnetworkHerald.
2012(45):96~99.
[5]XieXue-mei.
Experimentalstudyofglassdefectsdetectionsystem[D].
Qingdao:ChinaOceanUniversity.
2008.
05.
[6]ZhouYang.
Glassqualityonlinedetectionalgorithmresearchandsystemimplementation[D].
Wuhan:HuazhongUniversityofScienceandTechnology.
2006.
04.
- consistsqqshow.qq.com相关文档
- 会议qqshow.qq.com
- 学院qqshow.qq.com
- 会议qqshow.qq.com
- Symbolqqshow.qq.com
- 腾讯qqshow.qq.com
- qqshow.qq.com怎么弄QQ秀图标
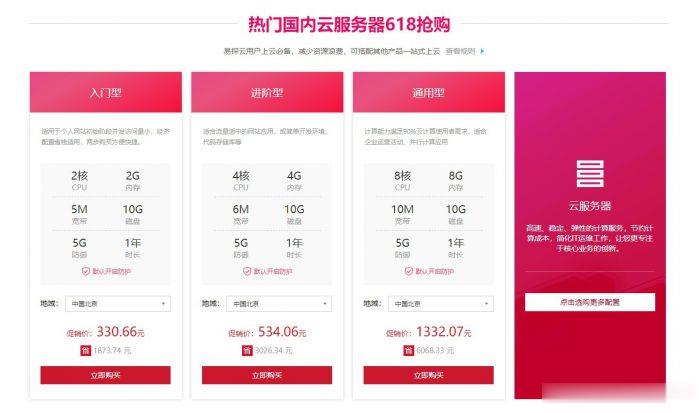
易探云2核2G5M仅330元/年起,国内挂机宝云服务器,独立ip
易探云怎么样?易探云是国内一家云计算服务商家,致力香港服务器、国内外服务器租用及托管等互联网业务,目前主要地区为运作香港BGP、香港CN2、广东、北京、深圳等地区。目前,易探云推出深圳或北京地区的适合挂机和建站的云服务器,国内挂机宝云服务器(可选深圳或北京地区),独立ip;2核2G5M挂机云服务器仅330元/年起!点击进入:易探云官方网站地址易探云国内挂机宝云服务器推荐:1、国内入门型挂机云服务器...
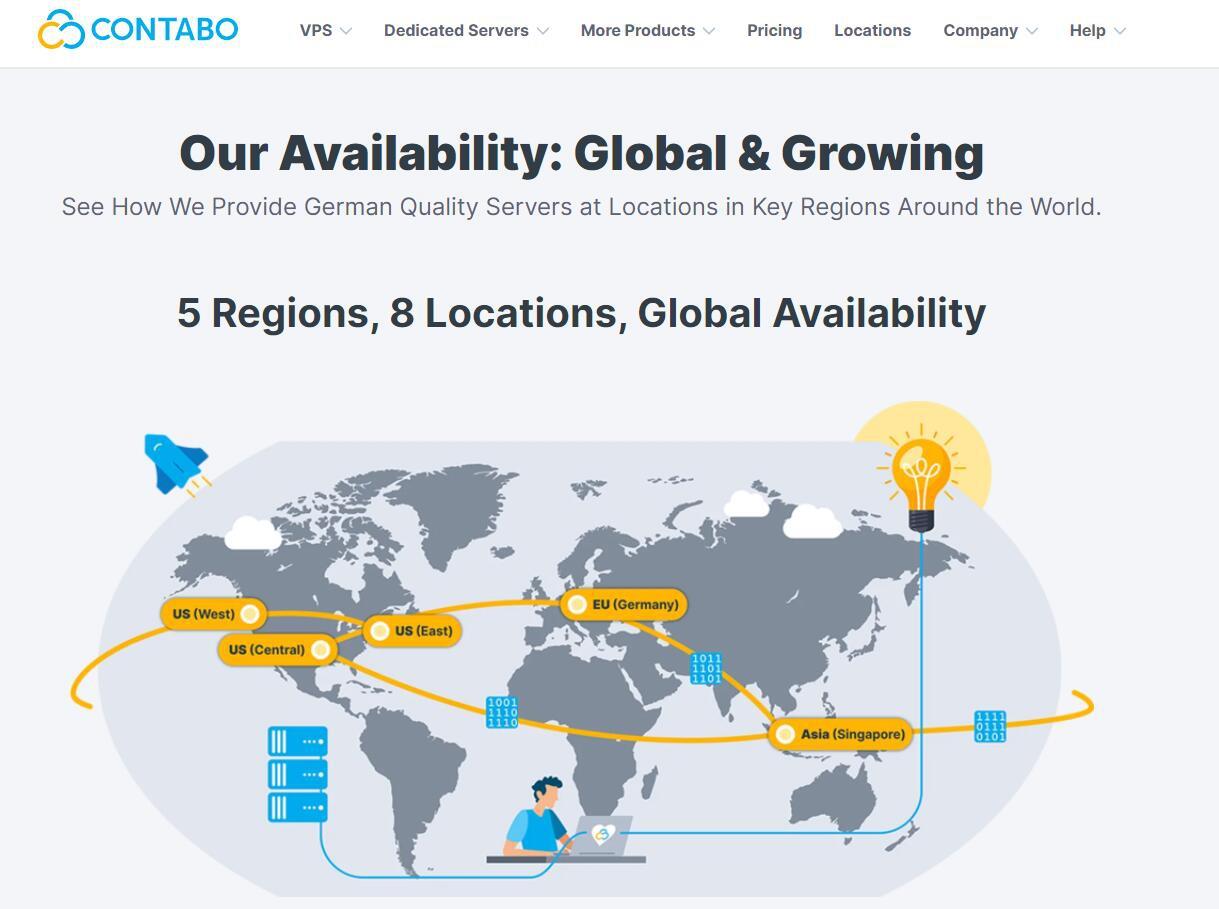
Contabo美国独立日促销,独立服7月€3.99/月
Contabo自4月份在新加坡增设数据中心以后,这才短短的过去不到3个月,现在同时新增了美国纽约和西雅图数据中心。可见Contabo加速了全球布局,目前可选的数据中心包括:德国本土、美国东部(纽约)、美国西部(西雅图)、美国中部(圣路易斯)和亚洲的新加坡数据中心。为了庆祝美国独立日和新增数据中心,自7月4日开始,购买美国地区的VPS、VDS和独立服务器均免设置费。Contabo是德国的老牌服务商,...
腾讯云轻量服务器老用户续费优惠和老用户复购活动
继阿里云服务商推出轻量服务器后,腾讯云这两年对于轻量服务器的推广力度还是比较大的。实际上对于我们大部分网友用户来说,轻量服务器对于我们网站和一般的业务来说是绝对够用的。反而有些时候轻量服务器的带宽比CVM云服务器够大,配置也够好,更有是价格也便宜,所以对于初期的网站业务来说轻量服务器是够用的。这几天UCLOUD优刻得香港服务器稳定性不佳,于是有网友也在考虑搬迁到腾讯云服务器商家,对于轻量服务器官方...
qqshow.qq.com为你推荐
-
云爆发云联惠是什么来的咏春大师被ko练咏春拳的杨师傅对阵散打冠军,注:是高龄级别被冠军级别打败了,那如果是咏春冠军叶问呢?更别说是李小mathplayerjavascript 如何判断document.body.innerHTML是否为空老虎数码我想买个一千左右的数码相机!最好低于一千五!再给我说一下像素是多少?甲骨文不满赔偿工作不满半年被辞退,请问赔偿金是怎么算的?百度关键词价格查询在百度设置关键字是怎么收费的lunwenjiancepaperrater论文检测准确吗336.com求那个网站 你懂得 1552517773@qqmole.61.com摩尔大陆?????www.baitu.com谁有免费的动漫网站?