correctedcornerradius
cornerradius 时间:2021-02-18 阅读:()
Chapter9.
FiveAxisToolPathGenerationMethodsOptimizedNC-toolpathgenerationfor5-axismachiningofcomplexsurfacesProf.
Dr.
Ir.
I-P.
Kruth(Jean-Pierre.
Kruth@mech.
kuleuven.
ac.
be)KatholiekeUniversiteitLeuven,Celestijnenlaan300B,3001Heverlee,BelgiumProf.
Dr.
Ir.
B.
Lauwers,IrP.
DejongheandIr.
1.
DotremontKatholiekeUniversiteitLeuven,Celestijnenlaan300B,3001Heverlee,BelgiumKeywords:CAD/cAM,5-axismillingAbstract:Thetoolpathgenerationmethoddescribedinthispaperisenhancingthesculpturedsurfacemachiningmethods,whichcanbefoundincommercialCAM-softwarepackages.
Toolaxisinclinationoptimizationisdonebasedonthepropertiesoftheunderlyingsurfaceandisaguaranteeforgouge-freeNC-toolpaths.
Thetoolinclinationvariesalongthetoolpathinsuchawaythattoolinclinationisoptimizedforeachindividualtoolposition.
TheproposedmethodusesprojecteddrivepatternsandisabletotakecareofmUltipleandeventrimmedpartsurfaces.
1.
INTRODUCTIONFiveaxismachiningoffreeformsurfaceshasmanyadvantagesifcylindricalortoricalcuttersareusedinsteadofballnosecutters.
Comparedtotraditionalthreeaxismachining,thematerialremovalrateincreasesandthemachiningtimereduces.
CommercialCAM-systemswithmulti-axiscapabilityareforcingtheoperatortogivethetoolacertainconstantleadand/ortiltangle(1)withrespecttothesurfacenormal.
Furtherasetofmultipleandtrimmedsurfacescanbemachinedwithinoneoperationthroughtheuseofdrivesurfaces.
Thedrivesurfaceisusedtogeneratetrajectoriesinacontactdrivenway,whicharethenprojectedontothepartsurfaces.
Thetoolorientationiscalculatedbasedeitheronthedrivesurfaceorthepartsurface.
Smallleadanglesarefavourabletothematerialremovalrate,surfaceroughnessandsurfaceaccuracy[2].
But,applyingasmallconstantleadanglealongthemillingpathcancausedifferentproblemslikegougingandvariationsinthescallopheight.
Asasolutionforthis,severalresearchershaveinvestigatedthedynamicoptimizationandadaptationofthetoolinclinationalongthetooltrajectory[1][2].
Themaindrawbackofmostofthesemethodsisthattheyarecontactdriven.
Thismeansthatthetoolisguidedalongtheisoparametriclinesofthepartsurface.
Asaresult,onlysinglesurfaceswithouttrimmingscanbemachined.
Thetoolpathgenerationmethoddescribedinthispaperoptimizesthetoolinclinationineachpointofthepartsurface.
ThesedevelopmentsfitintheframeoftheOPTIMACHproject.
ThegoalsofthisEU-fundedprojectare:Createreliablecollision-anderror-freeNC-programsthroughanon-lineclosedloopsimulationsystem.
Enhancemillingstrategiesinordertoimprovetheachievedsurfacequalitythroughoptimizingthetoolanglew.
r.
t.
theworkpieceandthestep-over.
Theoriginalversionofthischapterwasrevised:Thecopyrightlinewasincorrect.
Thishasbeencorrected.
TheErratumtothischapterisavailableatDOI:IFIPInternationalFederationforInformationProcessing199910.
1007/978-0-387-35392-0_40G.
J.
Ollingetal.
(eds.
),MachiningImpossibleShapesDependingontheprerequIsItesposedbytheusedCAD/CAMsystem,twomainapproacheshavebeenfollowedduringthedevelopment.
Thefirstapproachisbasedontheprototypesoftware,whichhasbeendevelopedinthepastatthedivisionPMAoftheK.
U.
Leuven[2].
Thesecondapproachisamorepracticalsolution,takingawaythedisadvantagesfromthefirstone.
Inbothcases,theinclinationadjustmentisdoneduringthetoolpathgenerationstep(greycolouredblockonFigure1)andnotduringNC-simulation,NC-verificationoronthemachine.
'"Loadll,20-'IFedral,200GOlDx,Y,z,i,j,k,Col/sonme$$llgeIN1T20M6IN2G1X,.
Y.
.
Z.
.
B.
.
C.
.
F300\.
jFigure1.
Overviewofthetoolpathgenerationprocessfora5-axisNC-program2.
FIRSTAPPROACH:NUMERICALOPTIMIZATIONBASEDONTHEANALYTICREPRESENTATIONOFTHEWORKPIECEGEOMETRY.
Forthisfirstapproach,thestandardCAD/CAM-routinesareusedtocalculateeachtoolposture.
Atoolpostureisthecombinationoftoolposition(xyz)andtoolorientation(ijk).
ThetoolinclinationascalculatedbytheCAD/CAM-systemisthenusedasthestartingvaluefortheoptimizationalgorithms.
TheroutinesofthestandardCAD/CAM-systemaregeneratingthetoolposturesinthefollowingmanner(Figure2):,A"".
.
/i)////.
/,///'//gJPSFigure2.
Methodforgeneratingtoolpostures344osAcertaininclinationangleisappliedtothetoolW.
r.
t.
thesurfacenormalofthecorrespondingtooltippointinthepartsurface.
Thetoolisthenprojectedontothepartsurface,whereacontactpoint(CP)isfound.
lftheinclinationangleappliedtothetoolislargeenough,thecontactpointwilllieinfrontofthecutter.
Theoptimizationalgorithm,explainedhereforacylindricalcutter,calculatesthemaximalangleoverwhichthecuttermayberotatedaroundthecontactpoint(CP)tofitascloseaspossibletothepartsurface.
Todothis,thealgorithmconstructsafunction8=f(u,v)representingtherelationshipbetweentheunderlyingsurfaceofthetoolandtheangleoverwhichthecutterisallowedtorotate.
ThisfunctionisthenminimizedtoobtaintheangleTheminimizationprocedureisbasedonatwo-dimensionalNewton-Raphsonmethodstartingfromagivenpointonthepartsurface.
Theresultofthisminimizationmethodisthenearestlocaloptimuminthesurroundingofthegivenpoint.
Figure3.
ElementarydiscinsidethecutterThesizeoftheunderlyingsurfaceforwhichthefunction8=f(u,v)isdefined,isdirectlyrelatedtothetooldiameter.
Thechanceforhavingmorelocalminimaincreaseswiththesizeofthecutter.
Asaconsequence,theanglehastobecalculatedformorethanonepoint,tobesuretofindthesmallestone.
Thisisdonebychoosinganumberofpointsonthebottomofthecylindricalcutter.
Foreachpoint,thefollowingisexecuted:1)Computetheshortestdistancetotheunderlyingpartsurface.
Consequently,thenearestpoint(PI)onthepartsurfaceisfound.
2)Theminimizationisof8=f(u,v)isdonestartingfromthepointPI.
3)Repeatstep2untiltherequestedaccuracyisachieved.
s:;pCPworlDCP_.
.
_.
.
_.
.
_.
.
_.
.
-··'1Z··_.
.
-,:/.
/OSPSThefulltoolwiththeestimatedtoolaxisisprojecteddownonthesurface.
ThisisdonebyusingthestandardCAD/CAMsystems'functionalityfortoolprojection.
Thetoolprojectionreturnsacontactpoint(UCP),whichmightactuallybeinglocatedeverywhereonthebottomofthecutter.
Thetoolaxisisthenac(justed(acertainvalueisaddedforB),basedontherelationshipbetweenthecontactpoint(CP)andthecontactpointreturnedbythetoolprojectionmethodUCP.
TheoalistoetCPascloseasossibletoUCP.
347PSThetoolisprojectedagainwiththenewlyfoundtoolaxis.
Doingthetoolprojectioneverytime,gougingisavoided.
Stepse,0andf)arerepeateduntilacertaincriterionisfulfilled.
Possiblecriterionsare,'UCPcloseenouhtoCP,iJ.
8notositiveanmore,.
.
.
Ingeneral,after2or3iterationstheoptimizedtoolpostureisfound.
Greatcareistakentonotrushthetoolaxisvariations.
Fastdecreasesofthetoolinclinationangle{)cancausethecuttertocutwithhisback.
Thisisnotfavourablefortoolsthatdonotcutwiththecentre(e.
g.
toricalcutters).
Quicklyincreasingthetoolinclinationontheotherhandcanhelpthecuttertoavoidgouging.
Asaresult,thedisturbanceofthetoolinclinationangle{)perdistanceunitislimitedtodifferentvaluesfordecreasingandincreasingtoolaxisinclinationvalues.
4.
\MACHININGRESULTSFortheexperimentalverificationoftheappliedmethod,aworkpiece(dimensions100x100mm)withaconcaveandconvexregion(Figure6)wasmilledoutofureolandaluminiumusingafive-axisMAHO600Cmillingmachine.
Duringtheexperiments,atoricalcutterwithadiameterof20mmandacornerradiusof4mmwasused.
Thenumberoftracksalwaysequalsto20.
ZCIYCFigure6.
Surfacewithconvexandconcaveregion348OneworkpiecewasmilledwiththestandardroutinesoftheCAD/CAM-system.
Forthistest,aminimalinclinationangleof9degreeshasbeenapplied.
Anotherworkpiecewasmilledusingtheoptimizedtoolaxisinclinationroutines.
Thescallopheightofthetwoworkpieceswasinvestigatedusinga3DcoordinatemeasuringmachineCOORD3equippedwithaWolf&Becklaser-scanningprobe.
Figure7showstherawscanningdata.
·202040608J100120·1·2·3Figure7.
Measuredprofileoftheworkpieceintheconvexregion.
Forthisspecificcase,thelargestbenefitoftheoptimizedmethodcomparedwiththestandardmethodwasfoundintheconvexregion.
Intheconcaveregionthecutterwillalwaysbeforcedtoalargertoolinclinationinordertopreventgouging.
5.
CONCLUSION&CONTINUATIONOFWORKTheproposedalgorithmshavebeenimplementedinsideacommercialCAD/CAMsystem.
Experimentsprovethealgorithmsfromthesecondapproachtoberobustandgeneralapplicable.
Sincetheoptimizationofthetoolpostureresultsinalargermaterialremovalrateandasmallerscallop,theneedforanaccuratestep-overcalculationalgorithmisoriginating.
ACKNOWLEDGEMENTSTheOPTIMACHprojectisbeingcarriedoutintheframeoftheIndustrialandMaterialsTechnologiesresearchandtechnologicaldevelopmentprogrammeoftheEuropeanCommunitywithafinancialECcontributionupto1.
923kECU.
MoreinformationaboutthisprojectcanbefoundontheOPTIMACH-webpages:APPENDIXDifferentangularsystemsareinusetodefinethetoolaxisinclination.
Themostpopularsystem,whichalsoisfoundinmostcommercialCAM-systemsisthelead-tiltsystem349(Figure8).
However,theinclination-screwsystemhasadvantagesinthewaythecalculationsaredone,butislessobviousfortheuseroftheCAM-system.
normalvectorZznormalvectortoolcenterpoint0toolcenterpoint0ycpfeeddirectionfeeddirectionFigure8.
Thelead-tiltsystem(lead=aandtilt=P)versustheinclination-screwsystem(inclination=eandscrew=(j).
Theabilityexiststoswitchfromoneangularsystemtoanotherusingtheseformulas:Table1.
TransistionformulasbetweenbothangularsystemsXinclination-screw=cosrp.
sin()X'ead-tilt=smaYinclination-screw=sinrp.
sin()Ylead-tilt=-cosa.
sinf3Zinclinalion-screw=cos()Zlead-tilt=cosa.
cosf3REFERENCES[I]ChoiB.
K.
,ParkJ.
W.
,JunC.
S.
,Cutter-locationdataoptimizationin5-axissurfacemachining,ComputerAidedDesign,vol.
25,no.
6,1993.
y[2]KruthJ.
-P.
,KlewaisP.
,OptimizationandDynamicAdaptationoftheCutterInclinationduringFive-AxisMillingofSculpturedSurfaces,AnnalsoftheCIRP,vol.
43/1,p.
443-448,1994[3]LeeY.
S.
,DecisionSupportEnvironmentforAdvancedMulti-axisCNCMachining,4thIndustrialEngineeringResearchConferenceProceedings,p.
260-268,1995.
[4]LeeY.
S.
,JiH.
,Surfaceinterrogationandmachiningstripevaluationfor5-axisCNCdieandmoldmachining,InternationalJournalofProductionResearch,vol.
35,no.
1,p.
22-252,1995[5]LiS.
X.
,JerardR.
B.
,5-axismachiningofsculpturedsurfaceswithaflat-endcutter,ComputerAidedDesign,vol.
26,no.
3,1994.
[6]MarciniakK.
,GeometricModellingforNumericallyControlledMachining,OxfordUniversityPress,1991.
[7]MarciniakK.
,Influenceofsurfaceshapeonadmissibletoolpositionsin5-axisfacemilling,ComputerAidedDesign,vol.
19,no.
5,1987.
[8]SaarA.
,LauwersB.
,DejongheP.
,Optimisedtoolpathgenerationmethodsforeconomicandcollisionfreemulti-axismachining,Proceedingofthe31stISATAconference,1998.
350
FiveAxisToolPathGenerationMethodsOptimizedNC-toolpathgenerationfor5-axismachiningofcomplexsurfacesProf.
Dr.
Ir.
I-P.
Kruth(Jean-Pierre.
Kruth@mech.
kuleuven.
ac.
be)KatholiekeUniversiteitLeuven,Celestijnenlaan300B,3001Heverlee,BelgiumProf.
Dr.
Ir.
B.
Lauwers,IrP.
DejongheandIr.
1.
DotremontKatholiekeUniversiteitLeuven,Celestijnenlaan300B,3001Heverlee,BelgiumKeywords:CAD/cAM,5-axismillingAbstract:Thetoolpathgenerationmethoddescribedinthispaperisenhancingthesculpturedsurfacemachiningmethods,whichcanbefoundincommercialCAM-softwarepackages.
Toolaxisinclinationoptimizationisdonebasedonthepropertiesoftheunderlyingsurfaceandisaguaranteeforgouge-freeNC-toolpaths.
Thetoolinclinationvariesalongthetoolpathinsuchawaythattoolinclinationisoptimizedforeachindividualtoolposition.
TheproposedmethodusesprojecteddrivepatternsandisabletotakecareofmUltipleandeventrimmedpartsurfaces.
1.
INTRODUCTIONFiveaxismachiningoffreeformsurfaceshasmanyadvantagesifcylindricalortoricalcuttersareusedinsteadofballnosecutters.
Comparedtotraditionalthreeaxismachining,thematerialremovalrateincreasesandthemachiningtimereduces.
CommercialCAM-systemswithmulti-axiscapabilityareforcingtheoperatortogivethetoolacertainconstantleadand/ortiltangle(1)withrespecttothesurfacenormal.
Furtherasetofmultipleandtrimmedsurfacescanbemachinedwithinoneoperationthroughtheuseofdrivesurfaces.
Thedrivesurfaceisusedtogeneratetrajectoriesinacontactdrivenway,whicharethenprojectedontothepartsurfaces.
Thetoolorientationiscalculatedbasedeitheronthedrivesurfaceorthepartsurface.
Smallleadanglesarefavourabletothematerialremovalrate,surfaceroughnessandsurfaceaccuracy[2].
But,applyingasmallconstantleadanglealongthemillingpathcancausedifferentproblemslikegougingandvariationsinthescallopheight.
Asasolutionforthis,severalresearchershaveinvestigatedthedynamicoptimizationandadaptationofthetoolinclinationalongthetooltrajectory[1][2].
Themaindrawbackofmostofthesemethodsisthattheyarecontactdriven.
Thismeansthatthetoolisguidedalongtheisoparametriclinesofthepartsurface.
Asaresult,onlysinglesurfaceswithouttrimmingscanbemachined.
Thetoolpathgenerationmethoddescribedinthispaperoptimizesthetoolinclinationineachpointofthepartsurface.
ThesedevelopmentsfitintheframeoftheOPTIMACHproject.
ThegoalsofthisEU-fundedprojectare:Createreliablecollision-anderror-freeNC-programsthroughanon-lineclosedloopsimulationsystem.
Enhancemillingstrategiesinordertoimprovetheachievedsurfacequalitythroughoptimizingthetoolanglew.
r.
t.
theworkpieceandthestep-over.
Theoriginalversionofthischapterwasrevised:Thecopyrightlinewasincorrect.
Thishasbeencorrected.
TheErratumtothischapterisavailableatDOI:IFIPInternationalFederationforInformationProcessing199910.
1007/978-0-387-35392-0_40G.
J.
Ollingetal.
(eds.
),MachiningImpossibleShapesDependingontheprerequIsItesposedbytheusedCAD/CAMsystem,twomainapproacheshavebeenfollowedduringthedevelopment.
Thefirstapproachisbasedontheprototypesoftware,whichhasbeendevelopedinthepastatthedivisionPMAoftheK.
U.
Leuven[2].
Thesecondapproachisamorepracticalsolution,takingawaythedisadvantagesfromthefirstone.
Inbothcases,theinclinationadjustmentisdoneduringthetoolpathgenerationstep(greycolouredblockonFigure1)andnotduringNC-simulation,NC-verificationoronthemachine.
'"Loadll,20-'IFedral,200GOlDx,Y,z,i,j,k,Col/sonme$$llgeIN1T20M6IN2G1X,.
Y.
.
Z.
.
B.
.
C.
.
F300\.
jFigure1.
Overviewofthetoolpathgenerationprocessfora5-axisNC-program2.
FIRSTAPPROACH:NUMERICALOPTIMIZATIONBASEDONTHEANALYTICREPRESENTATIONOFTHEWORKPIECEGEOMETRY.
Forthisfirstapproach,thestandardCAD/CAM-routinesareusedtocalculateeachtoolposture.
Atoolpostureisthecombinationoftoolposition(xyz)andtoolorientation(ijk).
ThetoolinclinationascalculatedbytheCAD/CAM-systemisthenusedasthestartingvaluefortheoptimizationalgorithms.
TheroutinesofthestandardCAD/CAM-systemaregeneratingthetoolposturesinthefollowingmanner(Figure2):,A"".
.
/i)////.
/,///'//gJPSFigure2.
Methodforgeneratingtoolpostures344osAcertaininclinationangleisappliedtothetoolW.
r.
t.
thesurfacenormalofthecorrespondingtooltippointinthepartsurface.
Thetoolisthenprojectedontothepartsurface,whereacontactpoint(CP)isfound.
lftheinclinationangleappliedtothetoolislargeenough,thecontactpointwilllieinfrontofthecutter.
Theoptimizationalgorithm,explainedhereforacylindricalcutter,calculatesthemaximalangleoverwhichthecuttermayberotatedaroundthecontactpoint(CP)tofitascloseaspossibletothepartsurface.
Todothis,thealgorithmconstructsafunction8=f(u,v)representingtherelationshipbetweentheunderlyingsurfaceofthetoolandtheangleoverwhichthecutterisallowedtorotate.
ThisfunctionisthenminimizedtoobtaintheangleTheminimizationprocedureisbasedonatwo-dimensionalNewton-Raphsonmethodstartingfromagivenpointonthepartsurface.
Theresultofthisminimizationmethodisthenearestlocaloptimuminthesurroundingofthegivenpoint.
Figure3.
ElementarydiscinsidethecutterThesizeoftheunderlyingsurfaceforwhichthefunction8=f(u,v)isdefined,isdirectlyrelatedtothetooldiameter.
Thechanceforhavingmorelocalminimaincreaseswiththesizeofthecutter.
Asaconsequence,theanglehastobecalculatedformorethanonepoint,tobesuretofindthesmallestone.
Thisisdonebychoosinganumberofpointsonthebottomofthecylindricalcutter.
Foreachpoint,thefollowingisexecuted:1)Computetheshortestdistancetotheunderlyingpartsurface.
Consequently,thenearestpoint(PI)onthepartsurfaceisfound.
2)Theminimizationisof8=f(u,v)isdonestartingfromthepointPI.
3)Repeatstep2untiltherequestedaccuracyisachieved.
s:;pCPworlDCP_.
.
_.
.
_.
.
_.
.
_.
.
-··'1Z··_.
.
-,:/.
/OSPSThefulltoolwiththeestimatedtoolaxisisprojecteddownonthesurface.
ThisisdonebyusingthestandardCAD/CAMsystems'functionalityfortoolprojection.
Thetoolprojectionreturnsacontactpoint(UCP),whichmightactuallybeinglocatedeverywhereonthebottomofthecutter.
Thetoolaxisisthenac(justed(acertainvalueisaddedforB),basedontherelationshipbetweenthecontactpoint(CP)andthecontactpointreturnedbythetoolprojectionmethodUCP.
TheoalistoetCPascloseasossibletoUCP.
347PSThetoolisprojectedagainwiththenewlyfoundtoolaxis.
Doingthetoolprojectioneverytime,gougingisavoided.
Stepse,0andf)arerepeateduntilacertaincriterionisfulfilled.
Possiblecriterionsare,'UCPcloseenouhtoCP,iJ.
8notositiveanmore,.
.
.
Ingeneral,after2or3iterationstheoptimizedtoolpostureisfound.
Greatcareistakentonotrushthetoolaxisvariations.
Fastdecreasesofthetoolinclinationangle{)cancausethecuttertocutwithhisback.
Thisisnotfavourablefortoolsthatdonotcutwiththecentre(e.
g.
toricalcutters).
Quicklyincreasingthetoolinclinationontheotherhandcanhelpthecuttertoavoidgouging.
Asaresult,thedisturbanceofthetoolinclinationangle{)perdistanceunitislimitedtodifferentvaluesfordecreasingandincreasingtoolaxisinclinationvalues.
4.
\MACHININGRESULTSFortheexperimentalverificationoftheappliedmethod,aworkpiece(dimensions100x100mm)withaconcaveandconvexregion(Figure6)wasmilledoutofureolandaluminiumusingafive-axisMAHO600Cmillingmachine.
Duringtheexperiments,atoricalcutterwithadiameterof20mmandacornerradiusof4mmwasused.
Thenumberoftracksalwaysequalsto20.
ZCIYCFigure6.
Surfacewithconvexandconcaveregion348OneworkpiecewasmilledwiththestandardroutinesoftheCAD/CAM-system.
Forthistest,aminimalinclinationangleof9degreeshasbeenapplied.
Anotherworkpiecewasmilledusingtheoptimizedtoolaxisinclinationroutines.
Thescallopheightofthetwoworkpieceswasinvestigatedusinga3DcoordinatemeasuringmachineCOORD3equippedwithaWolf&Becklaser-scanningprobe.
Figure7showstherawscanningdata.
·202040608J100120·1·2·3Figure7.
Measuredprofileoftheworkpieceintheconvexregion.
Forthisspecificcase,thelargestbenefitoftheoptimizedmethodcomparedwiththestandardmethodwasfoundintheconvexregion.
Intheconcaveregionthecutterwillalwaysbeforcedtoalargertoolinclinationinordertopreventgouging.
5.
CONCLUSION&CONTINUATIONOFWORKTheproposedalgorithmshavebeenimplementedinsideacommercialCAD/CAMsystem.
Experimentsprovethealgorithmsfromthesecondapproachtoberobustandgeneralapplicable.
Sincetheoptimizationofthetoolpostureresultsinalargermaterialremovalrateandasmallerscallop,theneedforanaccuratestep-overcalculationalgorithmisoriginating.
ACKNOWLEDGEMENTSTheOPTIMACHprojectisbeingcarriedoutintheframeoftheIndustrialandMaterialsTechnologiesresearchandtechnologicaldevelopmentprogrammeoftheEuropeanCommunitywithafinancialECcontributionupto1.
923kECU.
MoreinformationaboutthisprojectcanbefoundontheOPTIMACH-webpages:APPENDIXDifferentangularsystemsareinusetodefinethetoolaxisinclination.
Themostpopularsystem,whichalsoisfoundinmostcommercialCAM-systemsisthelead-tiltsystem349(Figure8).
However,theinclination-screwsystemhasadvantagesinthewaythecalculationsaredone,butislessobviousfortheuseroftheCAM-system.
normalvectorZznormalvectortoolcenterpoint0toolcenterpoint0ycpfeeddirectionfeeddirectionFigure8.
Thelead-tiltsystem(lead=aandtilt=P)versustheinclination-screwsystem(inclination=eandscrew=(j).
Theabilityexiststoswitchfromoneangularsystemtoanotherusingtheseformulas:Table1.
TransistionformulasbetweenbothangularsystemsXinclination-screw=cosrp.
sin()X'ead-tilt=smaYinclination-screw=sinrp.
sin()Ylead-tilt=-cosa.
sinf3Zinclinalion-screw=cos()Zlead-tilt=cosa.
cosf3REFERENCES[I]ChoiB.
K.
,ParkJ.
W.
,JunC.
S.
,Cutter-locationdataoptimizationin5-axissurfacemachining,ComputerAidedDesign,vol.
25,no.
6,1993.
y[2]KruthJ.
-P.
,KlewaisP.
,OptimizationandDynamicAdaptationoftheCutterInclinationduringFive-AxisMillingofSculpturedSurfaces,AnnalsoftheCIRP,vol.
43/1,p.
443-448,1994[3]LeeY.
S.
,DecisionSupportEnvironmentforAdvancedMulti-axisCNCMachining,4thIndustrialEngineeringResearchConferenceProceedings,p.
260-268,1995.
[4]LeeY.
S.
,JiH.
,Surfaceinterrogationandmachiningstripevaluationfor5-axisCNCdieandmoldmachining,InternationalJournalofProductionResearch,vol.
35,no.
1,p.
22-252,1995[5]LiS.
X.
,JerardR.
B.
,5-axismachiningofsculpturedsurfaceswithaflat-endcutter,ComputerAidedDesign,vol.
26,no.
3,1994.
[6]MarciniakK.
,GeometricModellingforNumericallyControlledMachining,OxfordUniversityPress,1991.
[7]MarciniakK.
,Influenceofsurfaceshapeonadmissibletoolpositionsin5-axisfacemilling,ComputerAidedDesign,vol.
19,no.
5,1987.
[8]SaarA.
,LauwersB.
,DejongheP.
,Optimisedtoolpathgenerationmethodsforeconomicandcollisionfreemulti-axismachining,Proceedingofthe31stISATAconference,1998.
350
- correctedcornerradius相关文档
- coppercornerradius
- achievedcornerradius
- 9.cornerradius
- tilescornerradius
- 截面cornerradius
- cornercornerradius
青云互联-洛杉矶CN2弹性云限时五折,9.5元/月起,三网CN2gia回程,可选Windows,可自定义配置
官方网站:点击访问青云互联官网优惠码:五折优惠码:5LHbEhaS (一次性五折,可月付、季付、半年付、年付)活动方案:的套餐分为大带宽限流和小带宽不限流两种套餐,全部为KVM虚拟架构,而且配置都可以弹性设置1、洛杉矶cera机房三网回程cn2gia 洛杉矶cera机房 ...
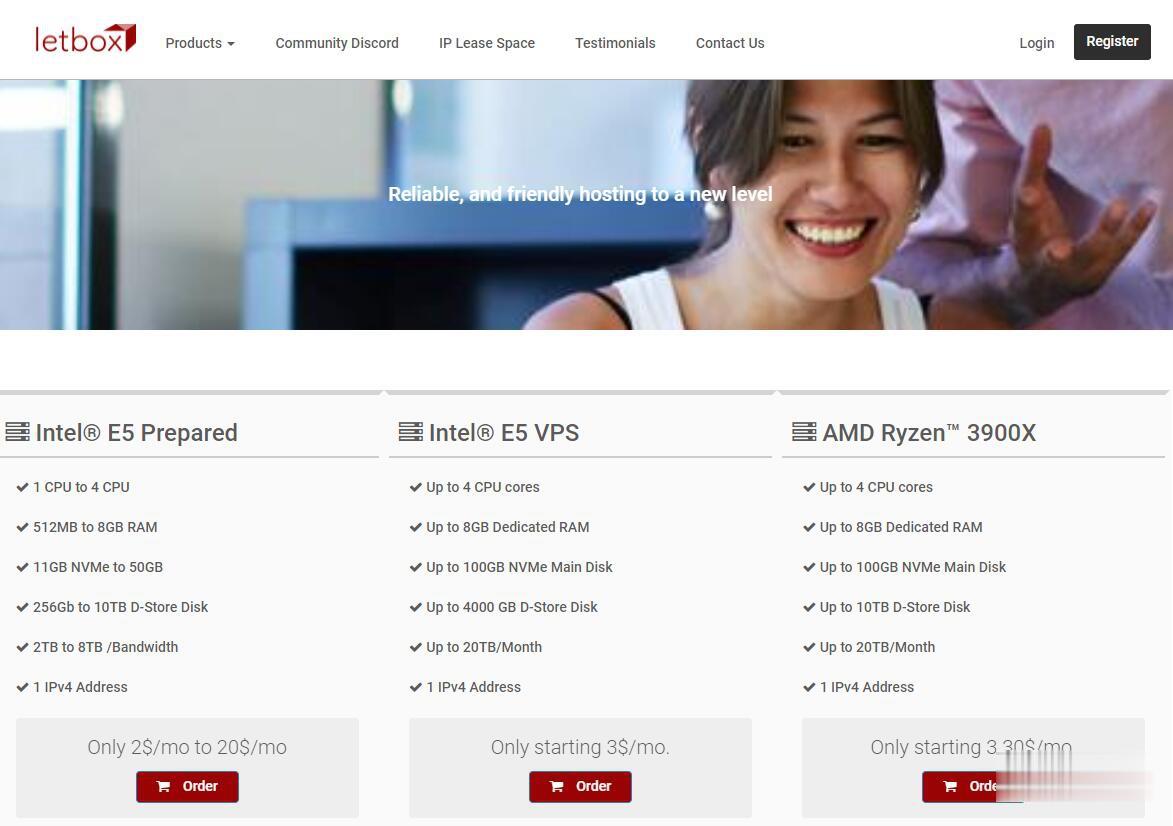
LetBox:美国洛杉矶/新泽西AMD大硬盘VPS,10TB流量,充值返余额,最低3.3美元两个月
LetBox此次促销依然是AMD Ryzen处理器+NVME硬盘+HDD大硬盘,以前是5TB月流量,现在免费升级到10TB月流量。另外还有返余额的活动,如果月付,月付多少返多少;如果季付或者半年付,返25%;如果年付,返10%。依然全部KVM虚拟化,可自定义ISO系统。需要大硬盘vps、大流量vps、便宜AMD VPS的朋友不要错过了。不过LetBox对帐号审核严格,最好注册邮箱和paypal帐号...
美国云服务器 1核 1G 100M 10G防御 39元/月 物语云计算
物语云计算(MonogatariCloud)是一家成立于2016年的老牌国人商家,主营国内游戏高防独服业务,拥有多家机房资源,产品质量过硬,颇有一定口碑。本次带来的是美国圣何塞 Equinix 机房的高性能I9-10980XE大带宽VPS,去程CN2GIA回程AS9929,美国原生IP,支持解锁奈飞等应用,支持免费安装Windows系统。值得注意的是,物语云采用的虚拟化技术为Hyper-V,资源全...
cornerradius为你推荐
-
cornerradius如何给TextView加个圆角?ghostxp3GhostXP3电脑公司特别版V499怎么安装自助建站自助建站哪个平台最好?http与https的区别http和https到底有什么区别啊???彩信中心移动的短信中心号码是多少宕机何谓宕机?ios系统iOS系统是什么bluestackbluestacks下载的东西在哪虚拟专用网虚拟专用网适用于什么行业系统分析员系统分析师是做什么 的